ROBOTICS / MACHINE LEARNING / March 10, 2024
Trashy: vision-guided robotics.
A Raspberry Pi and YOLOv3 prototype for automated object pickup.
Scroll horizontally to view the full diagram →
Camera The camera captures the area in front of the robotic arm.
PROJECT OVERVIEW
Purpose and implementation
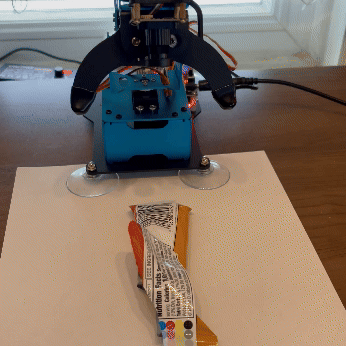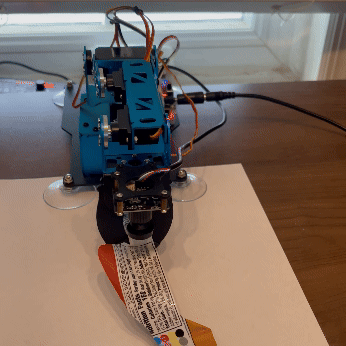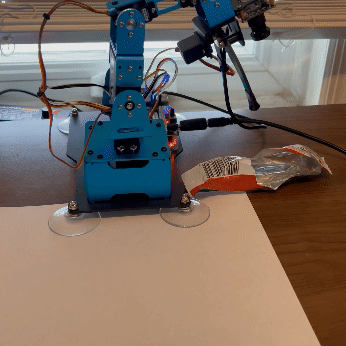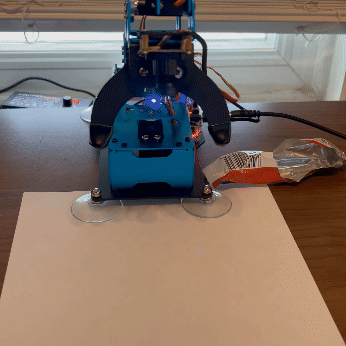
Trashy combines a pre-built robotic arm, a Raspberry Pi, and a custom YOLOv3 model. I developed software that connects camera-based object detection to arm movement, using desk trash as the target class.
Object detection and training data
I started with a pre-built robotic arm and a Raspberry Pi. The arm was designed for manual control, so most of the project involved writing code to connect visual detection with physical movement.
I trained a custom YOLOv3 weights file using 100 images of trash. A camera supplies images to the model, which estimates whether it has detected an object that should be picked up.
Detection threshold and arm control
When detection confidence exceeds 75%, the control software directs the arm to attempt a pickup. At 75% or below, the system continues observing.
The prototype connects object detection confidence to a physical action. The diagram shows the decision threshold and the two resulting control paths.
PROJECT DOCUMENTATION
Images and demonstrations
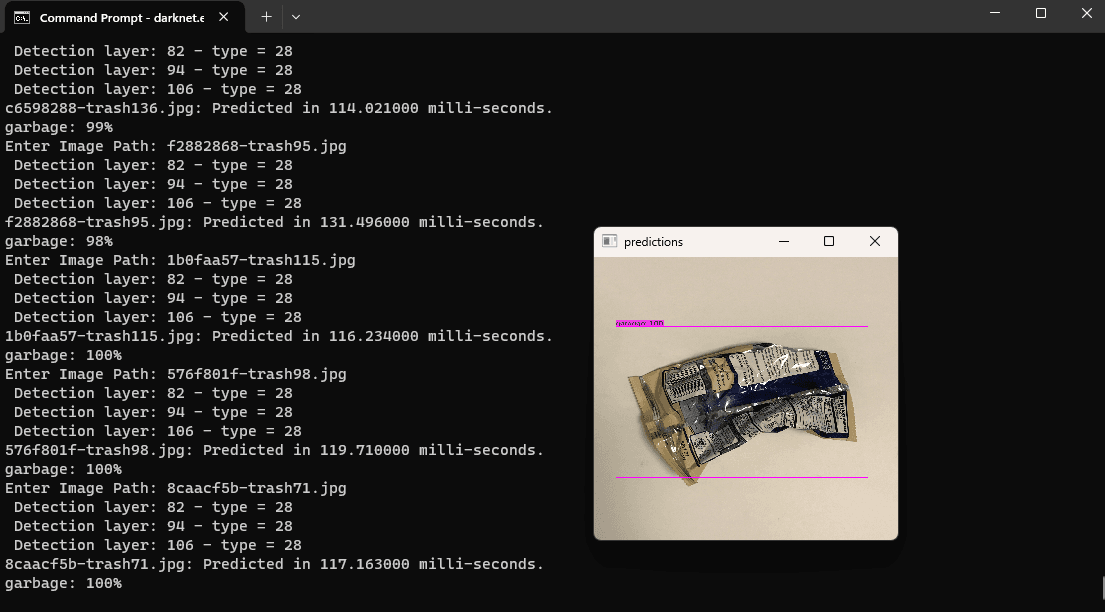
Show the Trashy demonstration +